Projects
The lab’s current and past projects. Most were run with industry or government partners, named on each entry.
Autonomous Transport for Harmonised Low-Carbon Operations and Sustainability (ATHLOS)
As part of the Imperial-TUM Joint Academy of Doctoral Studies, we are developing a unified framework that recovers fine-grained traffic metrics from coarse, aggregate traffic data, to measure the performance of transport systems as a whole.
Outputs include MaDE (NeurIPS 2026), which corrects trajectory predictions so they stay consistent with vehicle dynamics.
Collaborators: Prof Constantinos Antoniou (Technical University of Munich)
Sentiment Analysis of Commodity Markets Using Transformer-based Language Models
With colleagues at Dauphine University, we are developing language models to analyse sentiment relating to commodity supply and demand in news articles.
Collaborators: Prof Eugenia Passari (Dauphine University)
Vision-Language-Action Models for AV Scenario Interpretation
With Elm Europe, we are developing a vision-language-action framework for autonomous vehicle safety. We investigate how multimodal foundation models can interpret driving scenarios and inform responses to safety hazards. The project builds on our earlier work on autonomous vehicle simulation and risk metrics.
Collaborators: Elm Europe
Autonomous Truck Dispatch for Open-Pit Mines
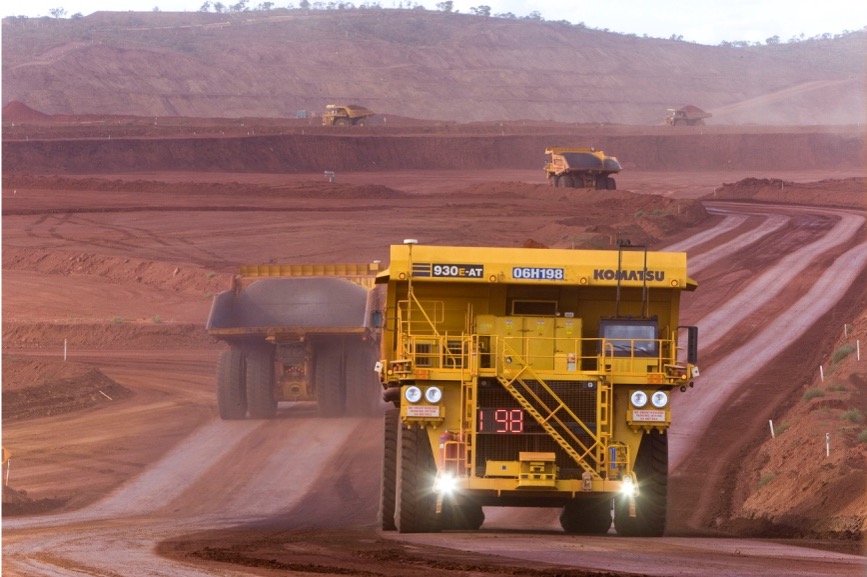
With Komatsu Ltd., we are developing algorithms for dispatching autonomous trucks in open-pit mines. The research combines reinforcement learning and combinatorial optimisation into decentralised control policies for large truck fleets.
Outputs include a fleet-sizing model for battery-electric haulage (Journal of Cleaner Production, 2026), which compares cost and emissions with diesel.
Collaborators: Komatsu Ltd.
DeepSafe: Narrowing the Reality Gap for AV Scenario Testing
We are part of DeepSafe, a CCAV-funded consortium working to narrow the gap between simulated and real-world testing of autonomous vehicles. Our contribution is a framework for quantifying autonomous vehicle risk.
Collaborators: dRISK, Claytex, rFpro
Scenario Gym: Lightweight Autonomous Driving Simulation
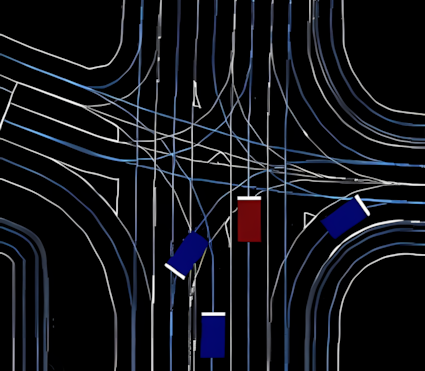
With dRISK and Hitachi, we developed Scenario Gym, a lightweight simulator for autonomous driving scenarios involving multiple types of road user. Scenario Gym is written in Python and uses an in-memory scenario representation compatible with OpenSCENARIO and OpenDRIVE standards. It supports both predefined trajectories and autonomous agents with specified goals.
Collaborators: dRISK, Hitachi Europe
Development Data Partnership
We lead Imperial College London's participation in the Development Data Partnership, a collaboration between international organisations and technology companies. The partnership supports the use of private sector data in research on public services and infrastructure.
Our researchers and MSc Transport with Data Science students work directly with World Bank project teams on global development and infrastructure management. Projects have covered trade, infrastructure development, disaster response, healthcare logistics and supply chain management.
Collaborators: The World Bank, Development Data Partnership
EV Impact Analysis for Retail Properties
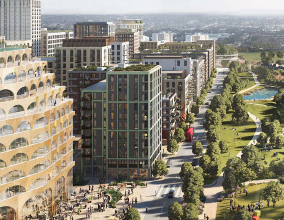
A retail property developer commissioned us to assess how increasing electric vehicle adoption would affect parking provision at shopping centres. Using a London shopping centre as a case study, we developed an agent-based model of customer behaviour to estimate the effects on shopping patterns, car park use, retailer logistics and profitability. An interactive dashboard allowed users to specify EV adoption scenarios, model charging provision and estimate investment returns.
Maritime 2050 Strategy Panel
Panagiotis Angeloudis was appointed by the UK Transport Secretary to the Maritime 2050 Expert Panel. The panel worked with industry, universities and policymakers to develop a long-term strategy for the UK maritime sector. The review considered how digital technologies and services could improve maritime operations.
Collaborators: UK Government, Department for Transport (DfT)
Fleet Routing for School Transport
A fleet services provider in the UAE commissioned us to develop a routing and scheduling platform for school buses. The platform combined pathfinding, location clustering and vehicle routing to plan school bus services for schools with more than 1,000 students.
It integrated with the provider’s fleet and customer management system, allowing managers to plan and adjust routes in real time to minimise students’ travel times.
D-RISK: De-risking Autonomous Vehicle Deployments
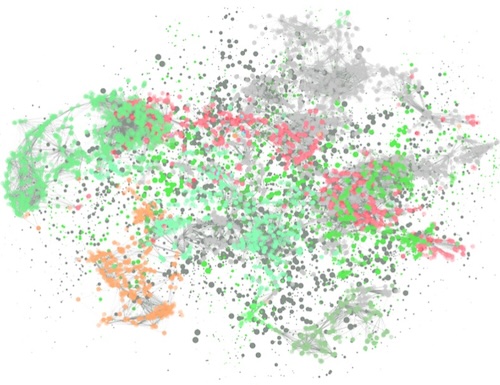
We partnered with dRISK, Claytex and DG Cities on a project funded by the UK's Centre for Connected & Autonomous Vehicles (CCAV). The project developed a safety framework and validation platform for testing autonomous vehicles in urban scenarios. We used graph theory to identify critical edge cases in a knowledge graph of real and simulated accident scenarios and assess the risk profiles of proposed autonomous vehicle systems.
Collaborators: dRISK, Claytex, DG Cities, CCAV
Parametric Modelling and Simulation for Urban Planning
With DG Cities, we developed a parametric modelling and simulation framework for assessing urban planning policies and regulations. It was used to evaluate autonomous vehicles, demand management measures and flexible infrastructure services.
Collaborators: DG Cities
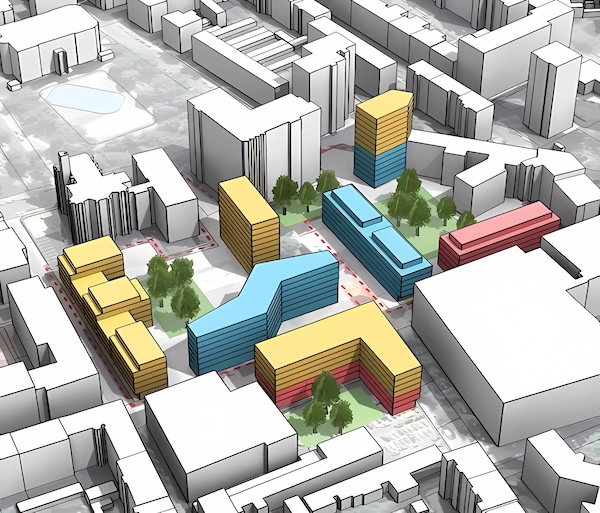
Intelligent Urban Mobility (IUMO): On-Demand Autonomous Transport
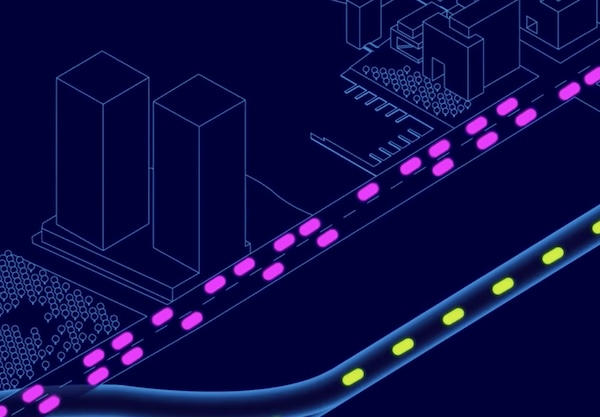
We advised PLP Architecture on Intelligent Urban Mobility (IUMO), a concept for demand-responsive autonomous electric vehicles running on a segregated track system. An Epic Games MegaGrant supported visualisation of the proposed system in Unreal Engine.
Collaborators: PLP Architecture, Reed Mobility
Future of Mobility Review for UK Government Office for Science
We supported the UK Government Office for Science (GO-Science) in their Future of Mobility review, part of the Foresight Programme. We reviewed methods for estimating transport supply and demand across the UK. We made recommendations on transport data collection, monitoring demand, dynamic intermodal routing and peer-to-peer transport services.
Collaborators: Government Office for Science (GO-Science), Foresight Programme
SHIFT: Autonomous Ridesharing Platforms
Funded by a £2 million Innovate UK grant, SHIFT modelled autonomous vehicle deployment in London and integration with public transport. We developed Delos, a simulation framework for public transport and ridesharing that we have since used in other autonomous transport research. Oxa used Delos to evaluate fleet performance and stress-test its fleet management platform. We also supported TfL in assessing how autonomous vehicle fleets could provide first- and last-mile connections to London’s public transport network.
Collaborators: Oxa, Bosch, Transport for London (TfL)

Electrification of Public Transport
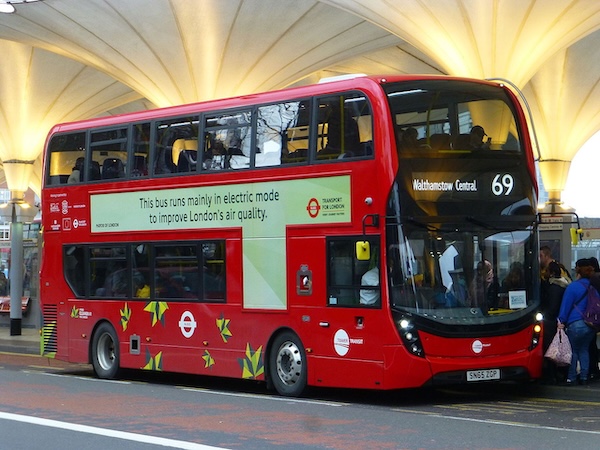
We developed a stochastic optimisation model for designing city-wide wireless charging infrastructure for electric buses. It considered wireless charging lanes that recharge buses while in motion, reducing reliance on stationary charging, and optimised infrastructure deployment across energy consumption scenarios. Results indicated potential annual cost savings of 24% compared with stationary charging.
Collaborators: DTE Network+, Transport for London (TfL)
Maritime Container Network Design Under Competition
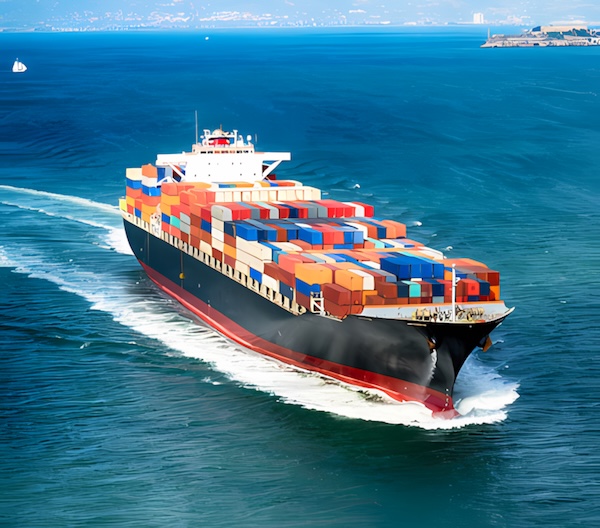
With the Department of Economics at the University of Padova, we developed a game-theoretic model for maritime container network design with competing shipping lines. Liner shipping firms in the model make sequential decisions about fleet investment, network design and freight rates. Our approach combines network optimisation with microeconomic principles to characterise market equilibria and evaluate how competition shapes maritime transport networks.
Collaborators: Prof Luciano Greco, University of Padova

Thames Tideway Intermodal Logistics Optimisation
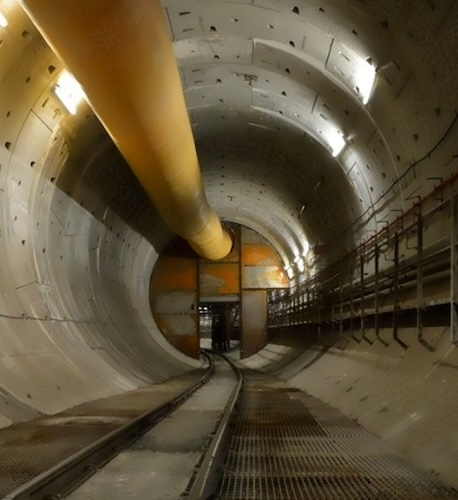
We developed a multimodal logistics optimisation model for the Thames Tideway tunnelling works. It had to meet a regulatory requirement to prioritise river barges over trucks to reduce emissions and road traffic. The model consolidated deliveries through transport mode selection and just-in-time scheduling, allowing for tides, bridge clearances, traffic congestion and changing material requirements. It combined GIS modelling, dashboards showing operational dependencies and a simulation-optimisation library.
Collaborators: Laing O'Rourke
Wuhan Logistics Cluster Masterplan
China's National Development and Reform Commission commissioned us to develop a masterplan for the Wuhan Logistics Cluster. The study assessed Wuhan's potential to become an international logistics hub within the Belt and Road Initiative, including direct connections to European rail networks.
Collaborators: National Development and Reform Commission (NDRC) China
Prefabrication Optimisation Toolkit for Hinkley Point C
We developed software to optimise the placement of prefabricated construction components at Hinkley Point C. It accounted for site capacity, crane lifting limits and scheduling constraints, and used component layouts from BIM models and evolutionary optimisation to plan casting schedules. Integration with construction scheduling tools allowed these plans to be revised as project schedules changed.
Collaborators: Bouygues Construction